The problem
A university UAV course needs a fleet that survives a semester of student handling, software that matches the papers being taught, and enough airframes that lab sessions aren’t bottlenecked on one aircraft. Consumer drones fail on the software; bespoke research builds fail on the fleet economics and the crash cost.
What the application demands
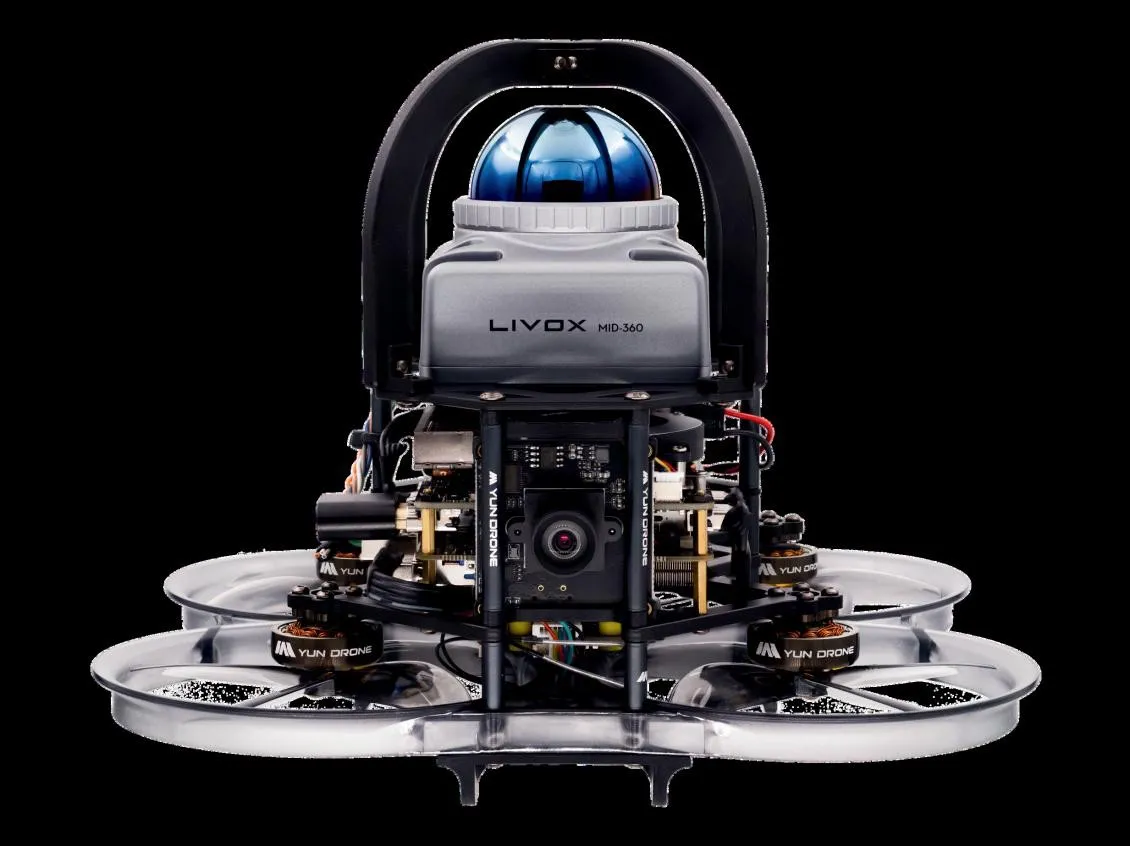
- Student-proof hardware — full carbon frames with propeller guards: a mid-air mistake is a non-event, and the aircraft goes back into the air, not into a repair queue.
- Real research stack — PX4 with all source open, Ubuntu 20.04 + ROS, MAVROS and the Sunray development package preinstalled. Students work with the same toolchain the research literature uses.
- Simulation-first workflow — the development environment supports Gazebo simulation, so students debug in sim before they ever fly.
- Progressive exercises — one-key takeoff / hover / velocity control interfaces and ready-made routines (waypoints, square / circular / hexagonal trajectories) give every lab session a working starting point.
- Fleet economics — per-seat pricing that fits a teaching budget, with one firmware image for the whole fleet.
Recommended configuration
| Role | Product | Why |
|---|---|---|
| Teaching fleet | Sunray-150 | 150 mm, guards, ~17 min hover — ideal per-seat aircraft for large courses |
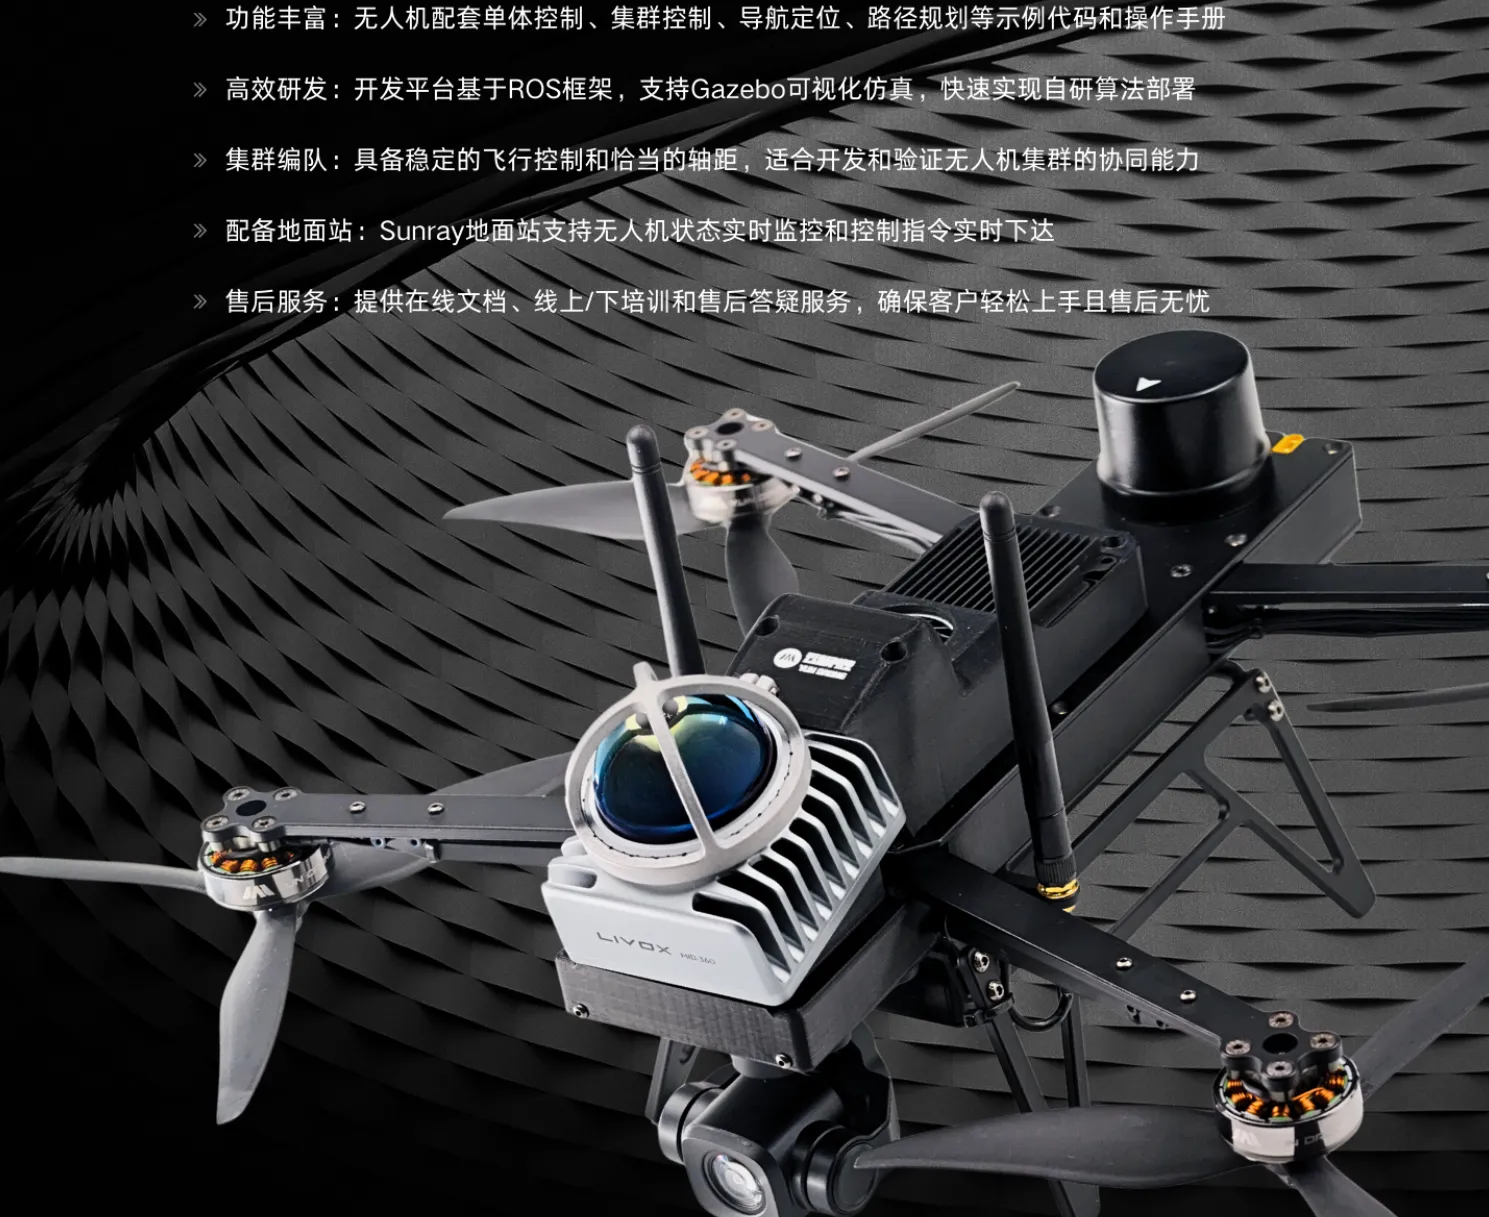
| Advanced / LiDAR labs | Sunray-300 | 300 mm with optional MID-360 + Fast-LIO2 / EGO-Planner for advanced SLAM and planning courses |
Every fleet purchase includes free online training (half a day) for instructors, and one year of online after-sales support keeps the lab running through the semester.