Sunray-300
NEWIn stockSunray-300
Research UAV Experimental Platform
From US$3,990
Ex Works Guangzhou (Incoterms 2020) · DDP to the EU on request · 5+ units −5%, 10+ −10%
Full price list & volume discounts →- Wheelbase
- 380 mm
- Takeoff weight
- ~2,400 g (with battery)
- Hover time
- ~25 min
- Battery
- 11,000 mAh
- RTK / GNSS
- u-blox ZED-F9P (outdoor)
Typical delivery 1–2 weeks worldwide · full manufacturer warranty
- Model
- Sunray-300
- Availability
- In stock
- Released
- 1 Dec 2025
- Price
- From US$3,990
Sold and supported by YivaDrone — authorized distributor of Yundrone. Factory stock, genuine parts, full manufacturer warranty. Questions? Email sales@yivadrone.com· Flying indoors in the EU? No registration or licence needed
About the Sunray-300
The Sunray-300 is an experimental platform designed for researchers and UAV developers, built on the Sunray open-source project. It ships with demo routines covering single-drone control, stereo visual positioning, depth-map obstacle avoidance and object detection — the building blocks most research projects start from.
Positioning, stated plainly. Outdoors, the built-in u-blox ZED-F9P delivers centimetre-level RTK accuracy. Indoors, no satellite receiver can work — navigation runs on the GPS-denied vision stack (optional stereo/depth camera pack) or an external motion-capture system, the same way every indoor research platform operates. We would rather tell you this before you buy than have you discover it after unboxing.
Software, stated plainly. The aircraft ships with Ubuntu 20.04 and the Sunray SDK — ROS 2 connected to PX4 through a preconfigured MAVLink↔DDS bridge. If your lab standardises on a newer LTS release, ask us for the current image status before ordering and you will get a straight answer.
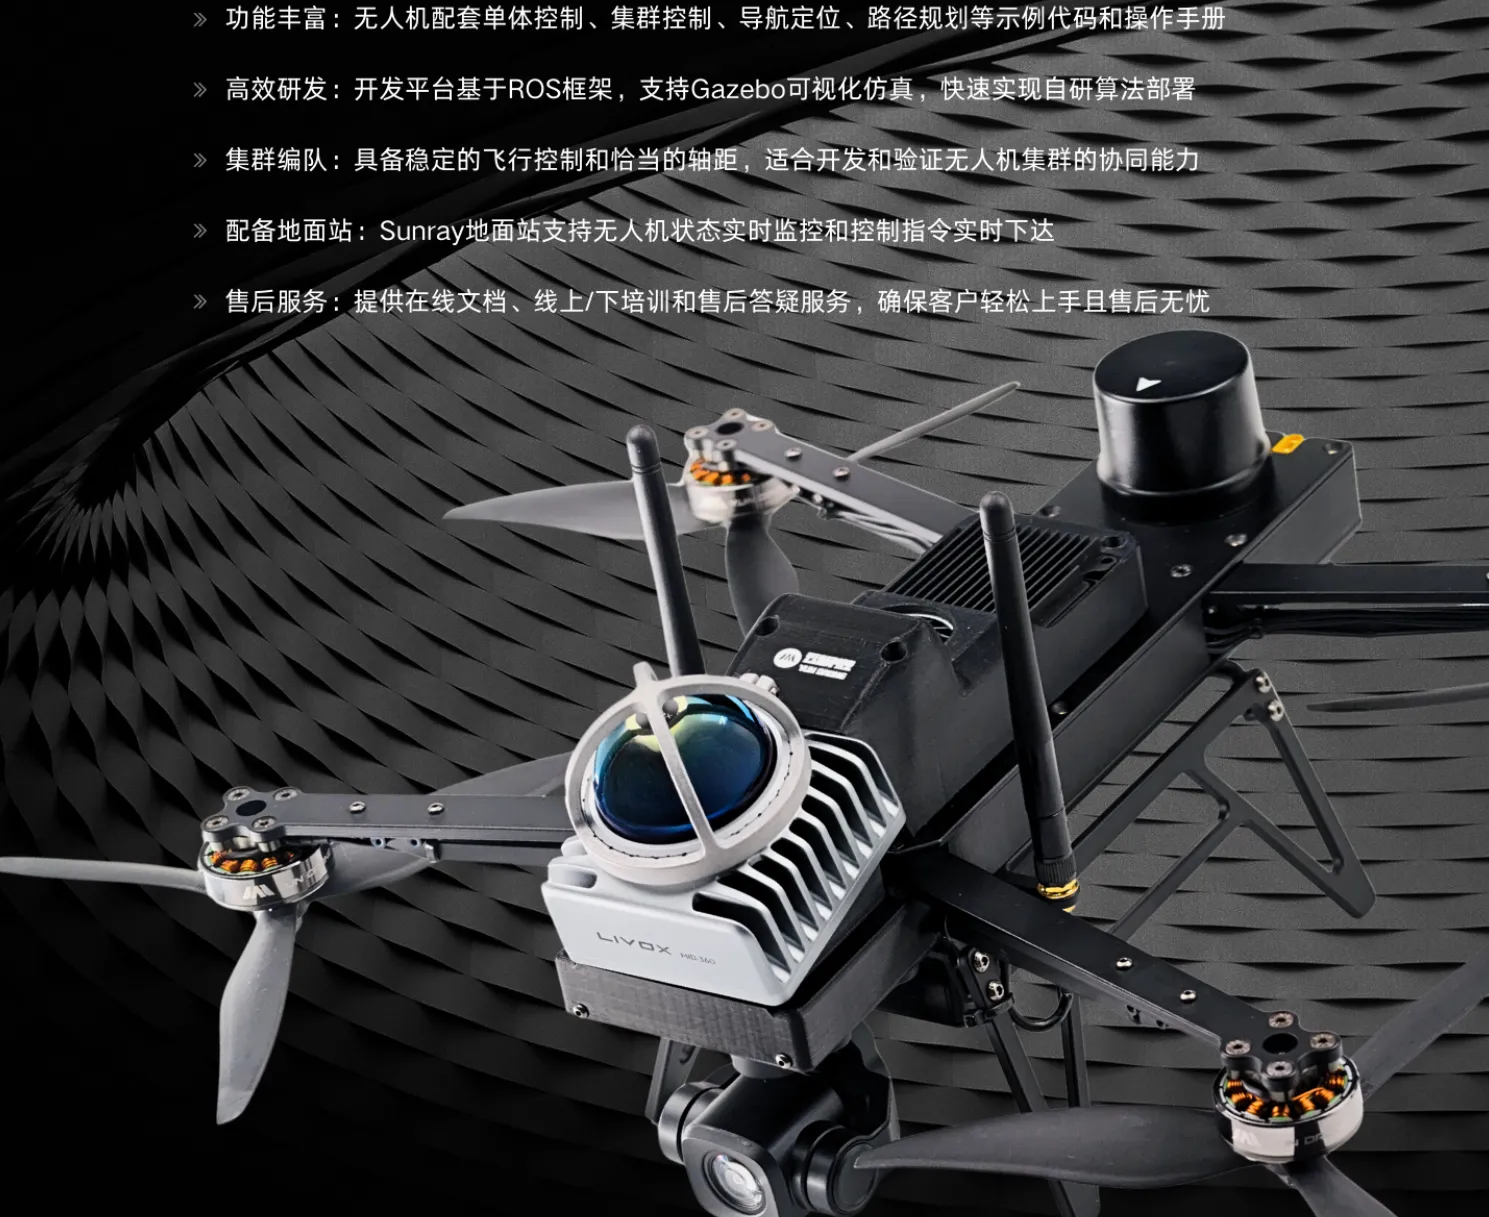
With a 4K stabilized gimbal camera and a 40 Mbps datalink on board, it is the platform for work that needs real sensors and real payloads, not just a flight controller on a bench.
Product highlights
PX4, fully open source
Open flight-control code you can inspect and patch — the same stack the research literature builds on.
Centimetre-level RTK outdoors
u-blox ZED-F9P on board for centimetre-level RTK positioning outdoors. Indoors there is no satellite signal — navigation runs on the GPS-denied vision stack (optional stereo/depth cameras) or an external motion-capture system.
4K gimbal camera
Sony 1/1.7-inch CMOS sensor with 8 MP effective resolution and 4K recording on a stabilized gimbal.
40 Mbps digital link
2.4–2.4835 GHz data and video link with air and ground units — telemetry, video and commands on one channel.
Optional stereo & depth vision
Add a 640×480 stereo camera or a 1280×720 depth camera (1920×1080 RGB) for indoor visual positioning and obstacle avoidance.
Ubuntu 20.04 with the Sunray SDK
ROS 2 connected to PX4 through a MAVLink↔DDS bridge, with routines for GPS-denied indoor positioning, 3D mapping and path planning. If your lab standardises on a newer LTS, ask us for the current image status before ordering.
Gallery
Technical specifications
| Wheelbase | 380 mm |
|---|---|
| Takeoff weight (with battery) | ~2,400 g |
| Hover time | ~25 min |
| Flight controller | PX4, fully open source |
| Power module | Two expansion output rails |
| Battery | 11,000 mAh |
| Remote controller | 10-channel, USB-C rechargeable |
| Datalink / video | 2.4–2.4835 GHz, max 40 Mbps |
| Gimbal camera | Sony 1/1.7" CMOS, 8 MP, 4K |
| Communication module | Air unit + ground unit |
| 3D LiDAR (optional) | Livox MID-360, 200,000 points/s, 10 Hz |
| RTK / GNSS | u-blox ZED-F9P built in |
| Stereo camera (optional) | 640 × 480 |
| Depth camera (optional) | Depth 1280 × 720, RGB 1920 × 1080 |
| Onboard software | Ubuntu 20.04, ROS 2 + MAVLink↔DDS bridge |
| Ground station | Status monitoring, video downlink, mission commands |
| Control interface | Arm, takeoff, hover, land, move, and more |
| Advanced routines | Indoor GPS-denied positioning, 3D mapping, path planning |
Typical applications
- GPS-denied indoor positioning research
- 3D mapping and path planning
- Object detection and tracking
- University UAV laboratories
Documents
- Sunray-300 Product Brochure (CN)v1.0 · 2026-09-01 · PDF · 3082 KB
Software & firmware
Hosted by the Sunray open-source project.
Accessories & spare parts
Reference prices shown in CNY — contact us for bundle pricing with a platform order.
Multi-output power module
¥100
Wide-input power distribution for onboard computers, flight controllers and RTK sensors.
- Input
- 4–6S (13–28 V wide input), XT60
- Output
- 2× 12 V + 1× 5 V, 5 A max per channel
- Supports
- RDK X3, NVIDIA Jetson Orin NX, Pixhawk, RTK
Sunray-150 brushless motor
¥125
Custom motor for 5-inch ultralight long-range builds, 3–4 inch toothpick frames and ducted aircraft.
- Motor size
- 2104
- KV
- 3000
- Weight
- 15.9 g
- Battery
- 3–4S
MID-360 LiDAR adapter cable
¥300
Replaces the original aviation-plug connector with a GH1.25 — same pinout as the stock 1-to-3 harness, smaller and lighter for UAV use.
Inquire →7075 aluminum M3 standoff
¥3
Aviation-grade 7075 aluminum through-hole standoff, anodized matte finish.
- Material
- 7075 aluminum alloy
- Finish
- Anodized, matte
- Thread
- M3
Request a quote — Sunray-300
Model is prefilled. Tell us your quantity and configuration (base / LiDAR / options) and we'll reply within one business day.